
Harsh Muriki
I am a PhD student in Robotics at Georgia Tech advised by Dr. Sonia Chernova and Dr. Sidd Karamcheti, where I work on memory, retrieval, and planning for VLMs and VLAs. Previously an Applied Scientist Intern at Amazon Lab126 (Fauna Robotics), building multi-modal memory for VLM planners.
✉️ [email protected]
Research Interest: Memory & Retrieval for Robot Policies, Vision-Language-Action Models (VLAs) & VLMs, Task and Motion Planning (TAMP), Long-Horizon Mobile Manipulation, Imitation & Reinforcement Learning, 3D Perception
Publications
Evaluating Long-Horizon Robot Planning under Uncertainty
H. Muriki, G. Aravindan, Y. Zheng, and S. Chernova
4th Workshop on Learning Effective Abstractions for Planning (LEAP), CoRL 2026 in Austin, USA
Exploring User Perceptions of Proactive Robot Assistance In-The-Wild
M. Patel, K. Ramachandruni, H. Muriki, N. Nguyen, A. Balasubramanian, and S. Chernova
2027 IEEE International Conference on Robotics and Automation (ICRA) (Under Review)
Point Cloud-Based Deep Learning for Automated Dormant Pruning of Peach Trees
H. Muriki, A. Asfour, R. George, J. Knapp-Wilson, D. Chavez, and A. Hu
2027 IEEE International Conference on Robotics and Automation (ICRA) (Under Review)
Research Projects
Test-Time Memory Retrieval for VLAs
With zero demonstrations of a new task, the robot retrieves contact-and-motion sub-trajectories from past experience on other objects and uses them in context to act. Benchmarked against STRAP, appearance-based, and random retrieval in RoboCasa365 and LIBERO.
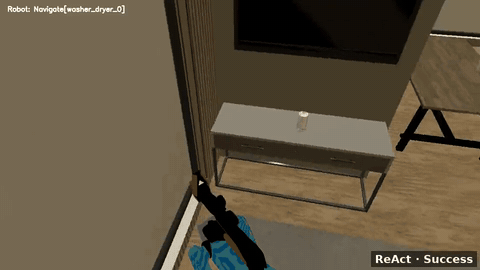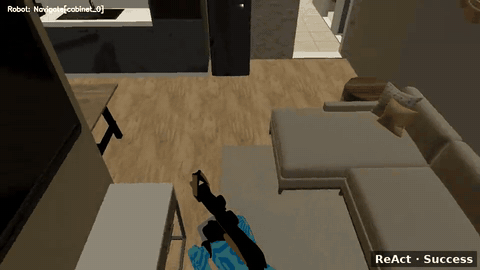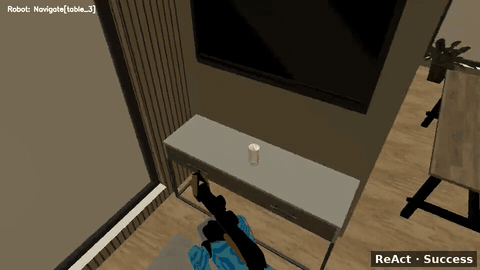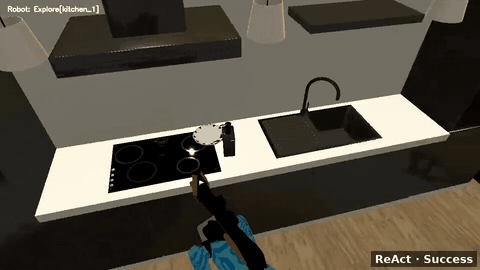
Evaluating Long-Horizon Robot Planning under Uncertainty
LEAP Workshop @ CoRL 2026. A benchmark of seven long-horizon household tasks in Habitat that vary the robot's initial memory and the environment, evaluating ReAct, VLM-TAMP, and Tru-POMDP across 1,350 episodes.
View ProjectExplainable Long-Horizon TAMP in Unseen Environments
An explainable task and motion planning framework for long-horizon mobile manipulation that combines belief-space planning with interpretable decision traces, integrating symbolic task structure with uncertainty-aware planning in Habitat.
Course Projects

IRL Project: HINTeract-Hint-Driven Hierarchical Learning for Robotic Furniture Assembly
Built a modular HRL framework where a Sawyer arm requests on-demand human hints to grasp, align, and insert parts, achieving sample-efficient toy-table assembly in Robosuite with 260 expert demos and open-sourced code.
View Project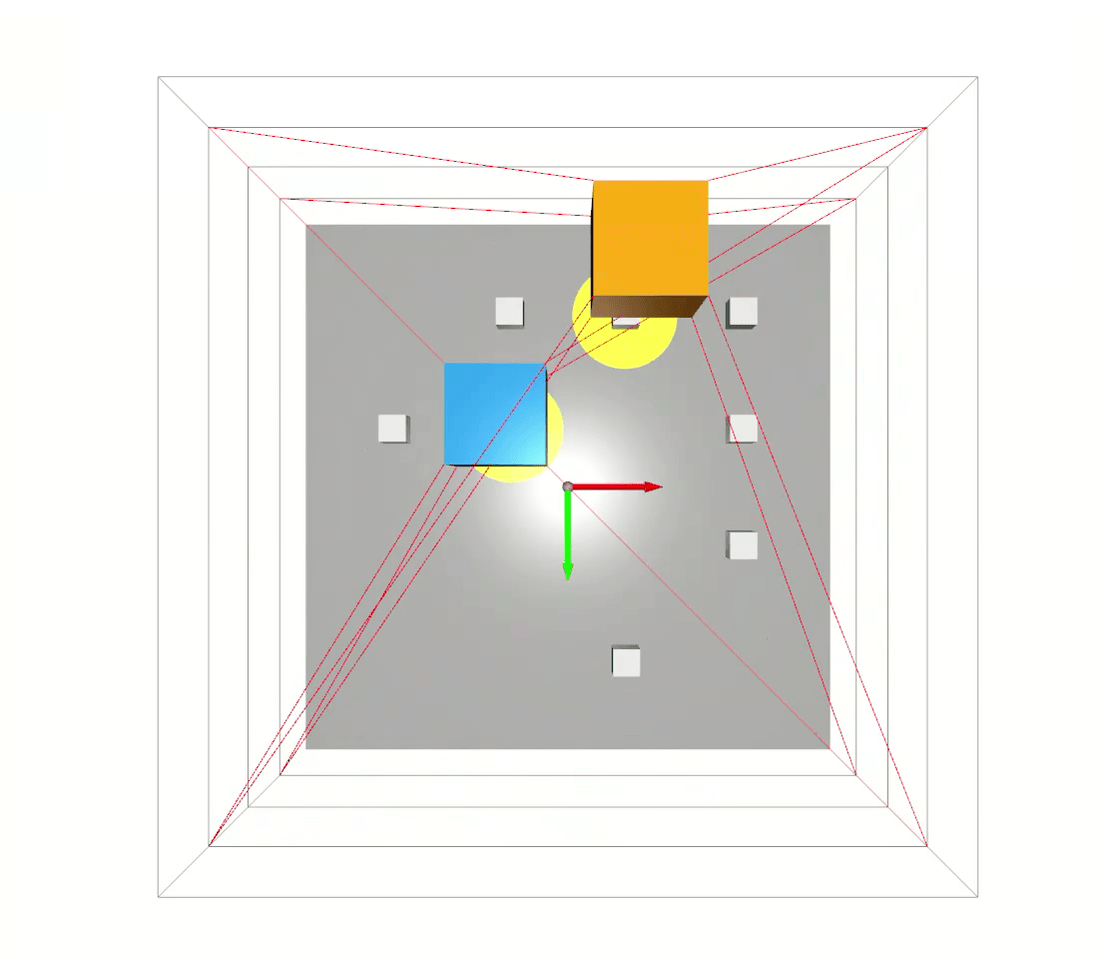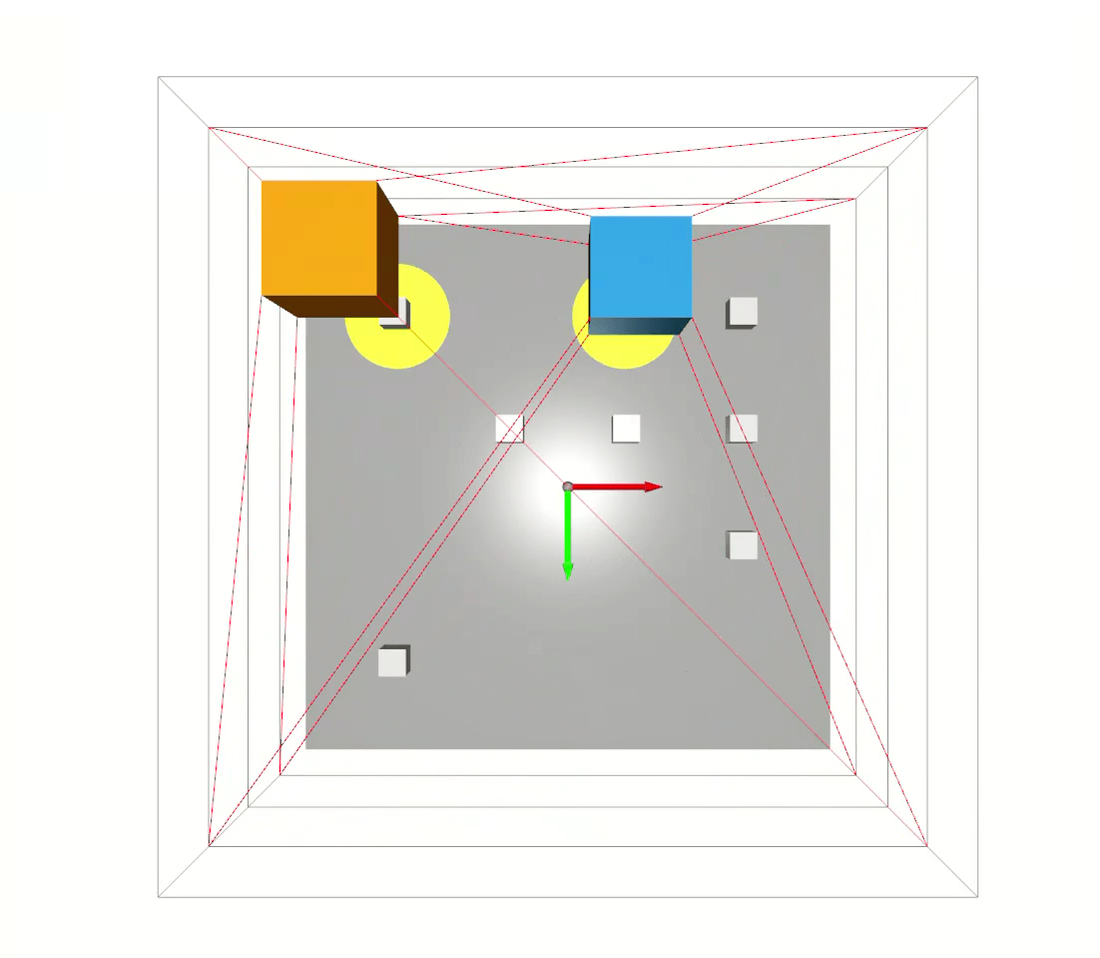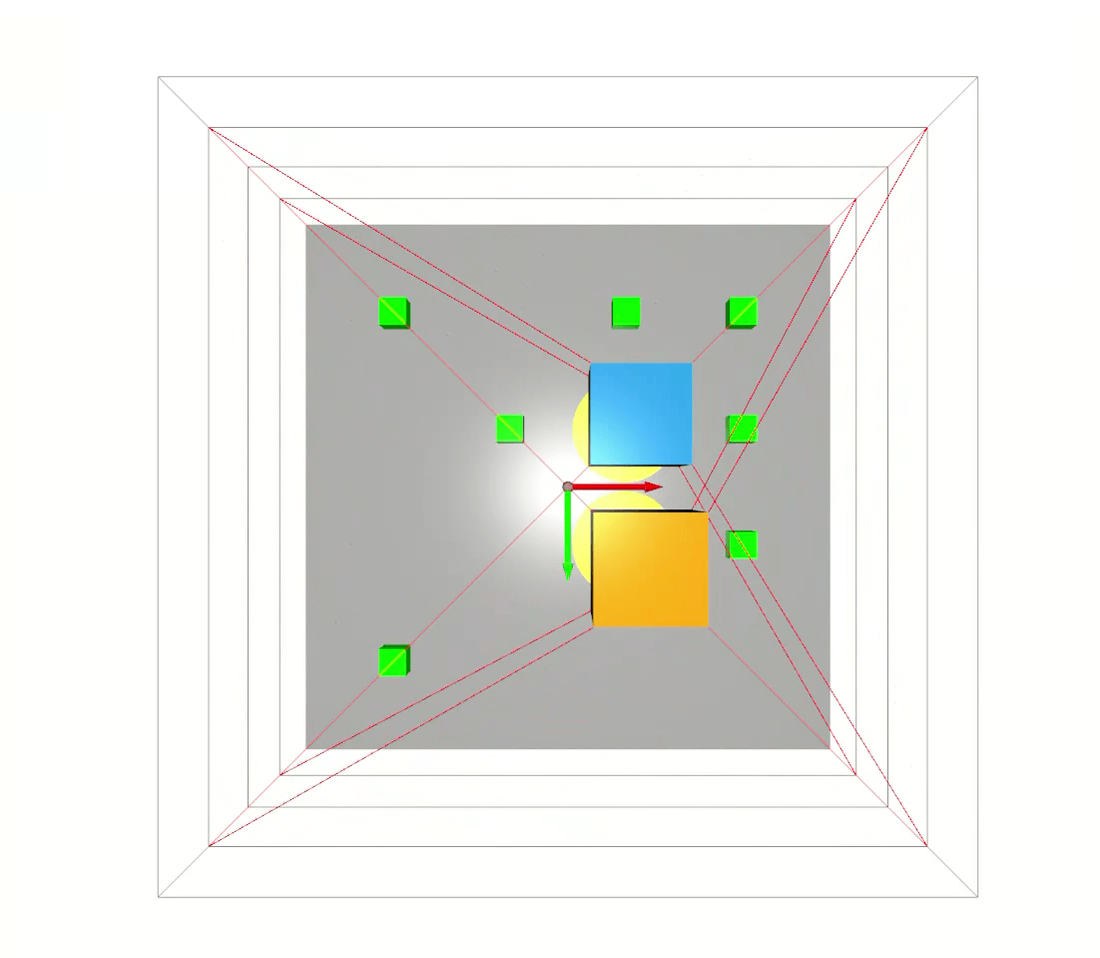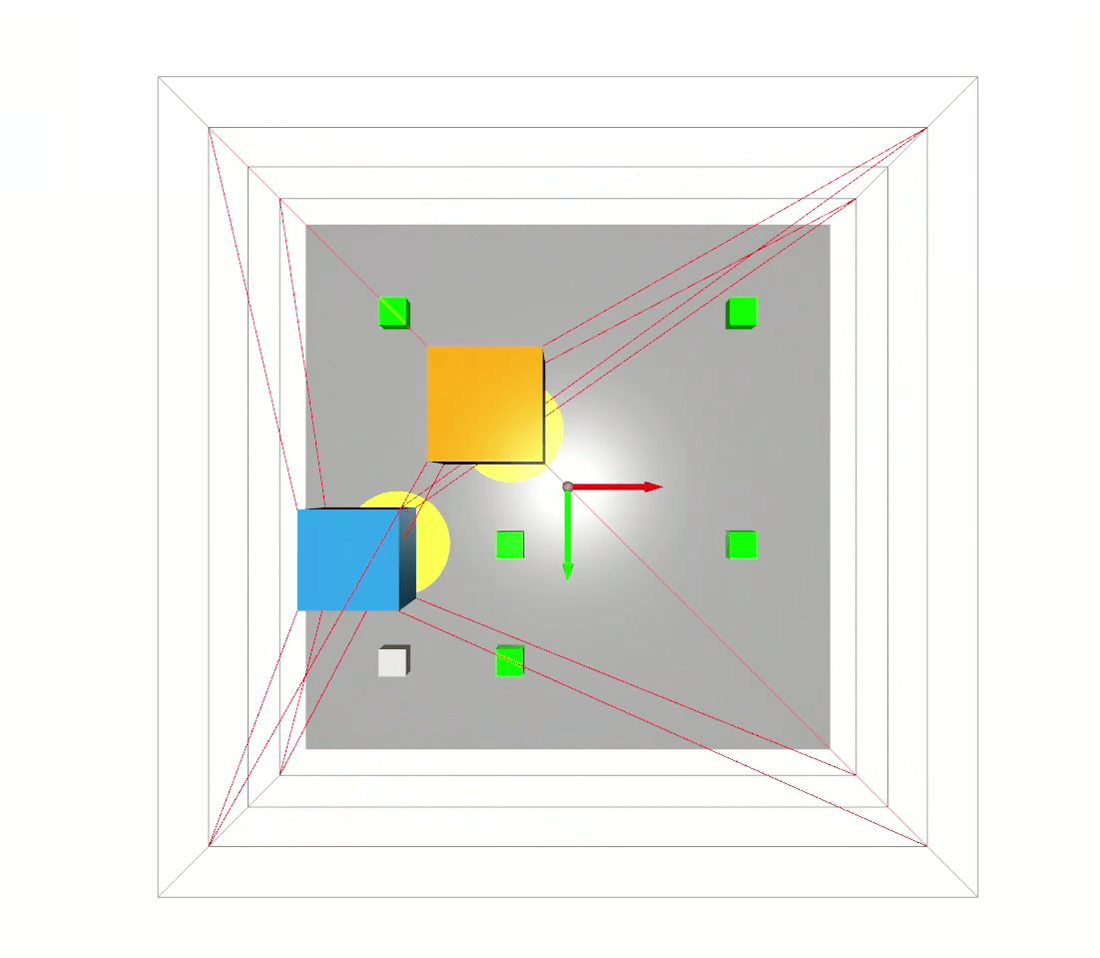
MRS Project: CableCrop RL-Multi-Cable Robot Planning for Agricultural Data Capture
Designed a coordinated RGB+hyperspectral cable-robot pair and trained PPO/MAPPO agents in simulation to maximize crop coverage and data richness while dodging collisions for scalable precision-ag monitoring.
View Project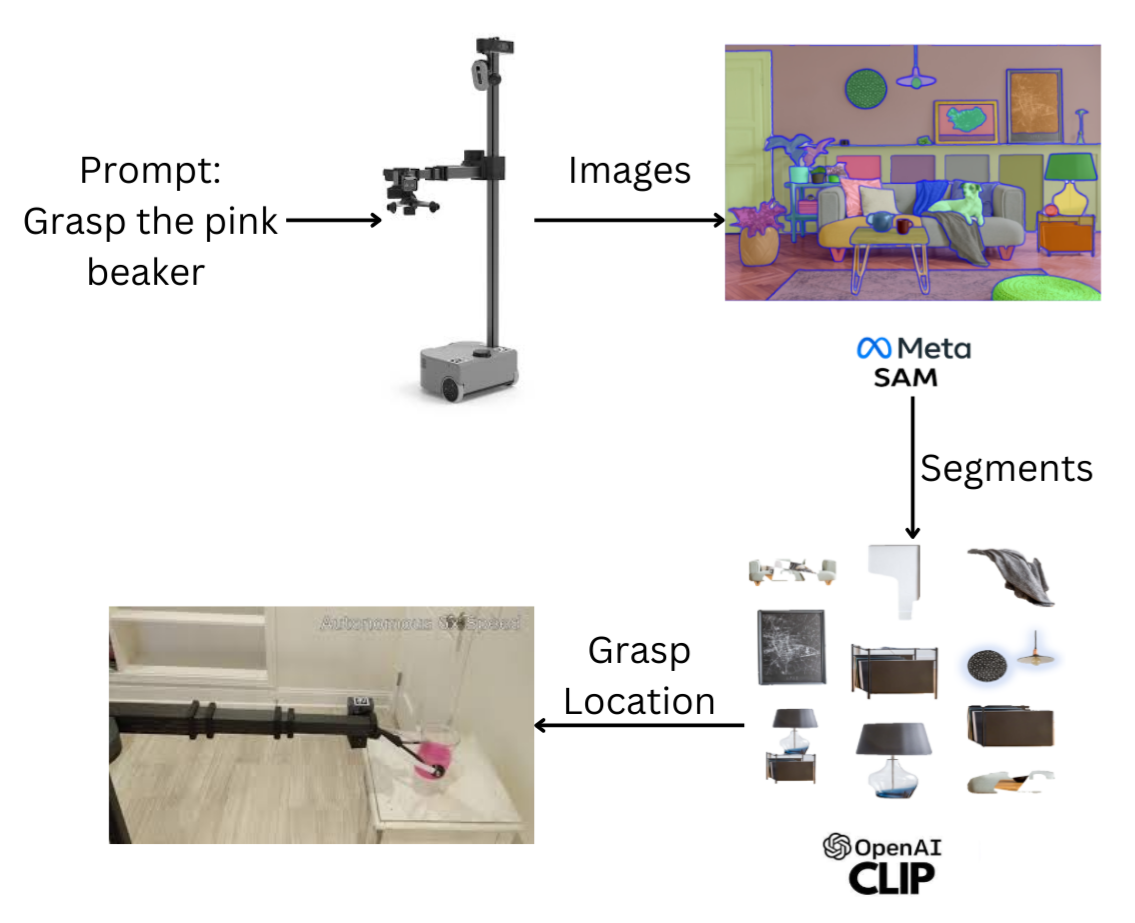
HRI Project: LM-NavGrasp-Language-Guided Navigation & Grasping on Hello Robot Stretch
Developed a pipeline that fuses large vision-language models (CLIP + SAM) with ROS-Nav so Stretch can parse a natural-language object description, autonomously navigate to the correct table, and execute a grasp on the specified item in cluttered lab scenes.
View ProjectTeaching
CS 3630: Introduction to Perception and Robotics
Teaching Assistant · Fall 2025, Spring 2026